Mobstr
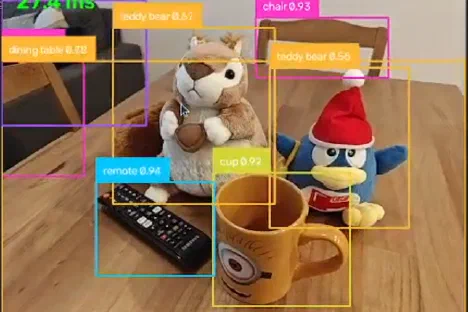
A low-latency Android camera streaming app for computer-vision development, built around hardware H.264 encoding and RTSP.
2026
- C++
- Android
- H.264
- RTSP
Portfolio
Selected work across computer vision, machine learning, and robotics.
A low-latency Android camera streaming app for computer-vision development, built around hardware H.264 encoding and RTSP.
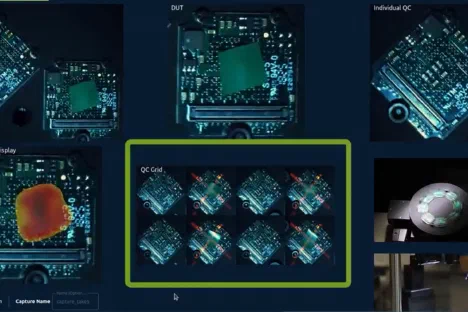
Unsupervised anomaly detection demo for inVISION Days.
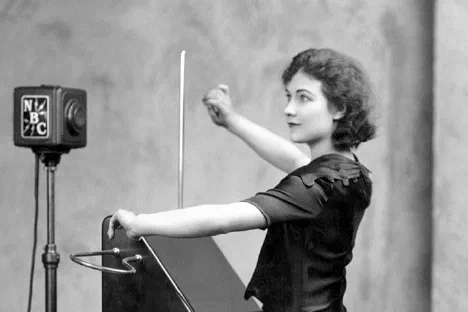
A musical instrument you can play in your browser.
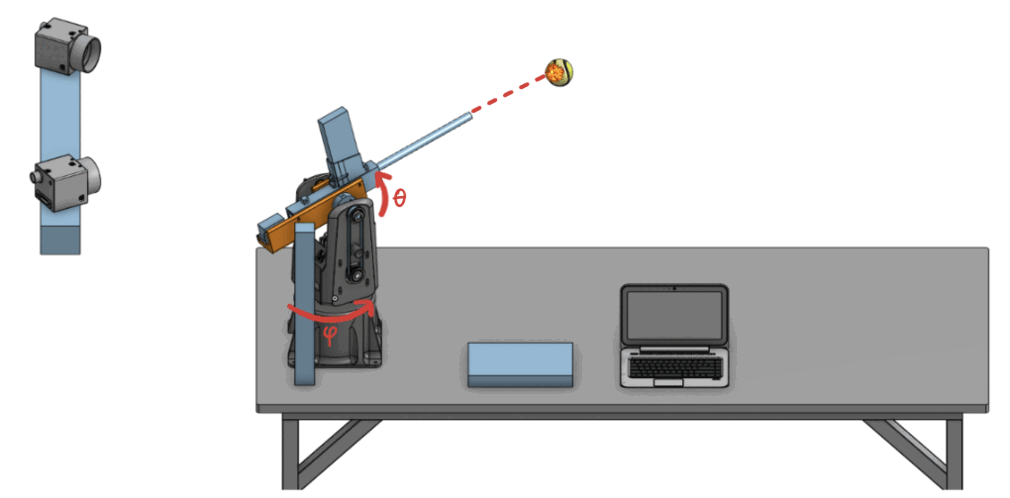
Built an automated ballistic interceptor that used a high-speed stereo vision system and OpenCV to predict 3D ball trajectories for interception with a projectile from a stepper‑driven BB launcher.
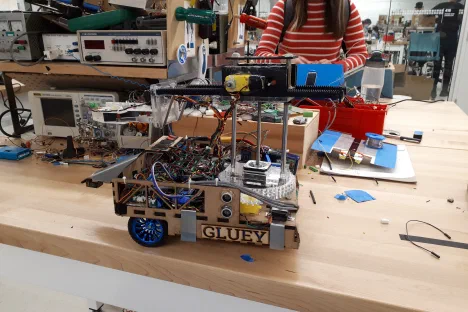
Built an autonomous differential‑drive robot built in a six‑week UBC ENPH 253 course. It uses IR, ultrasonic, and magnetic sensors with PID control to navigate an obstacle course and collect objects with a four‑DOF claw.
Trained an agent in Gazebo to autonomously navigate a 3D obstacle course (imitation learning) and correctly read random license plates (CNN) while avoiding collisions.